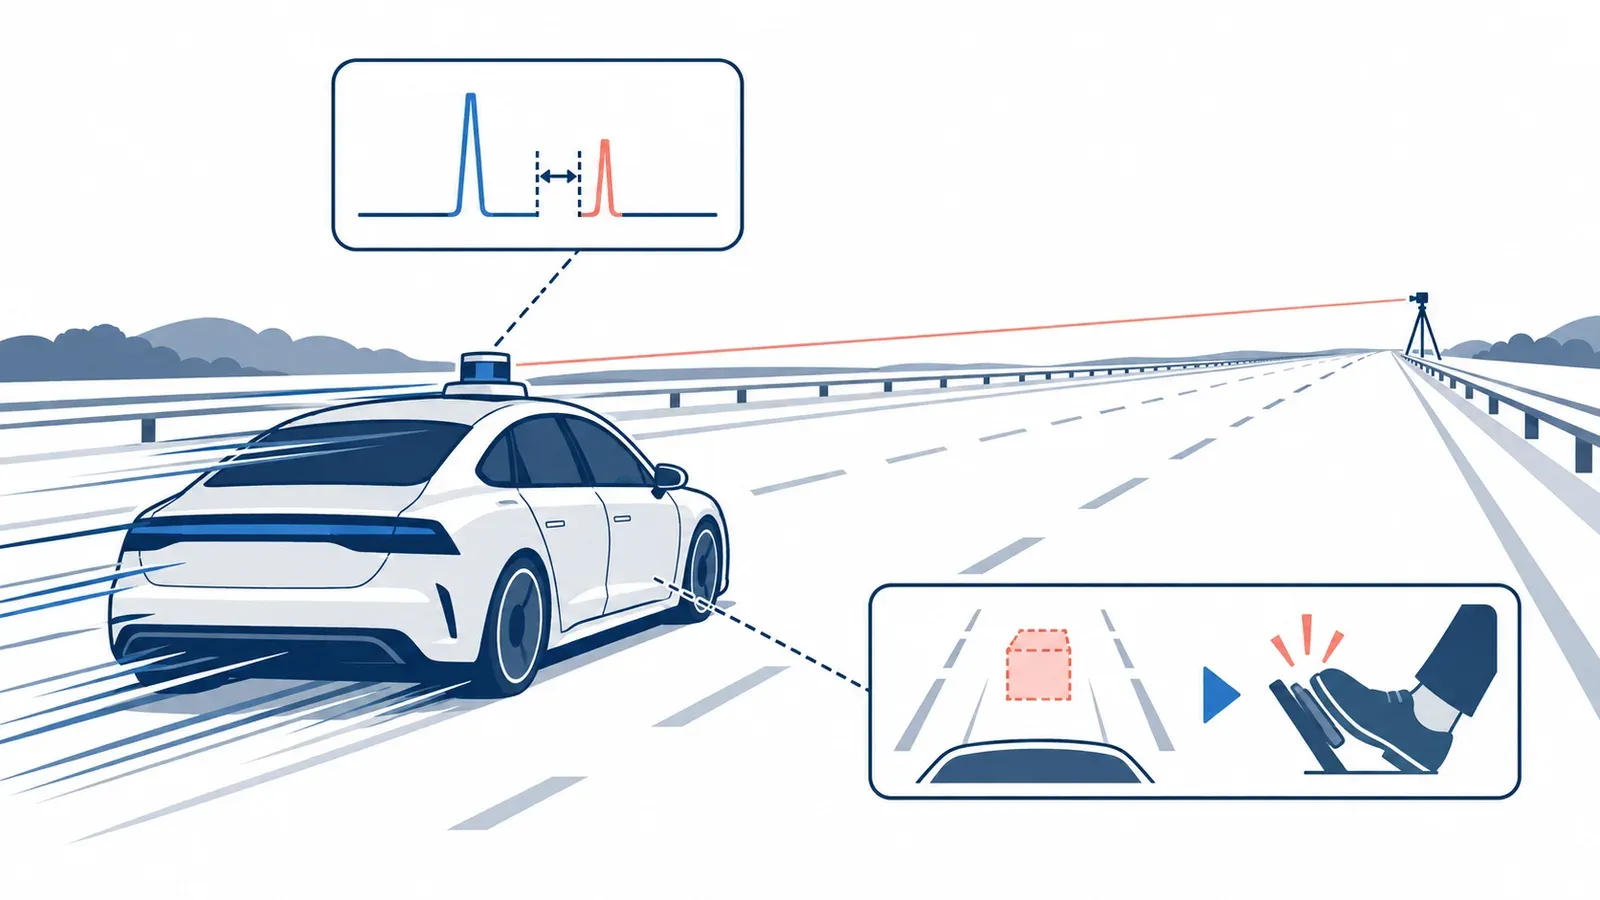
Examines the practical feasibility of LiDAR spoofing attacks on autonomous driving vehicles at realistic high speeds and long distances. Reveals that spoofing remains effective under conditions previously assumed to be safe, challenging existing security assumptions.