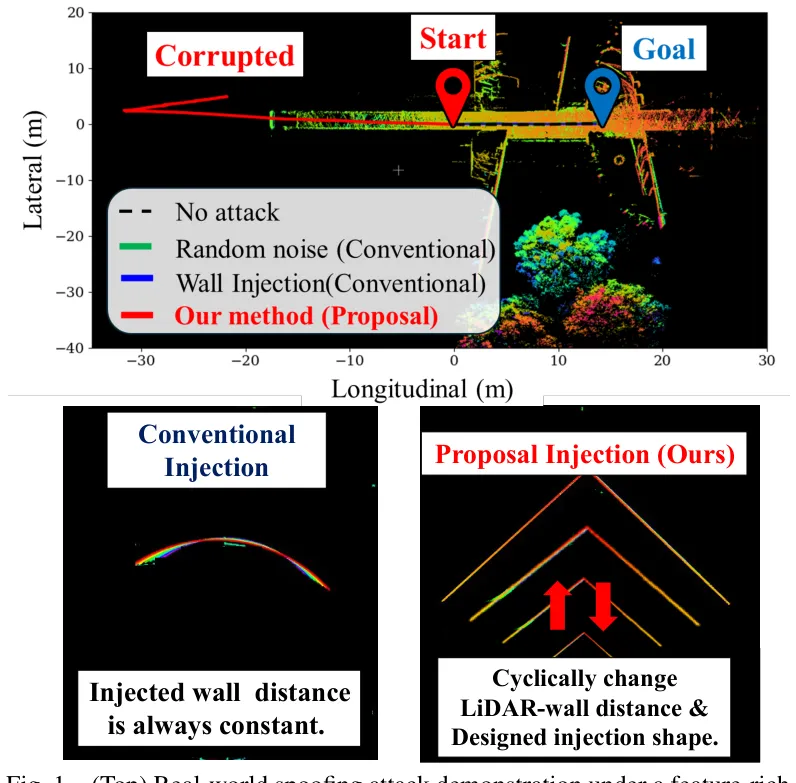
D-SLAMSpoof overcomes the fundamental limitation of prior LiDAR spoofing attacks — ineffectiveness in feature-rich environments such as urban areas and indoor spaces. By designing spatially structured injection shapes and temporally coordinated dynamic patterns guided by scan matching principles, the attack successfully manipulates SLAM-based localization regardless of environmental complexity. The paper also proposes ISD-SLAM, a practical defense that detects and mitigates spoofing-induced drift using only onboard inertial dead-reckoning signals, requiring no additional hardware.