概要
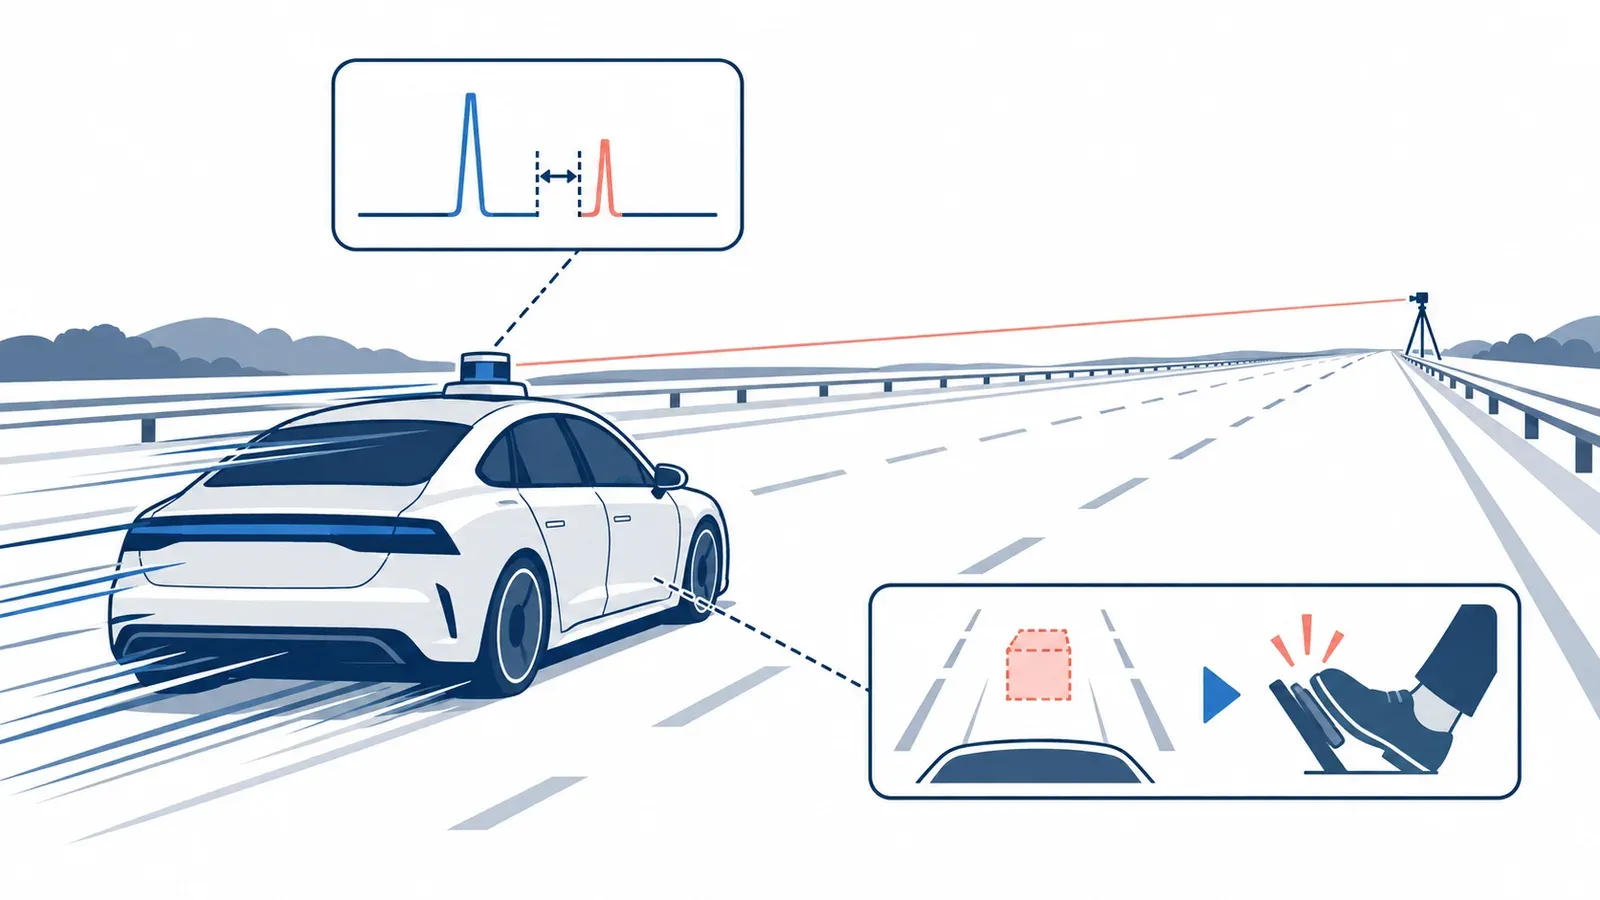
高速走行・長距離条件下での自動運転車両に対するLiDARスプーフィング攻撃の現実的な有効性を検証した研究。これまで安全と想定されていた条件下でも攻撃が成立することを明らかにし、既存のセキュリティ前提を覆す実験的証拠を提示する。
Examines the practical feasibility of LiDAR spoofing attacks on autonomous driving vehicles at realistic high speeds and long distances. Reveals that spoofing remains effective under conditions previously assumed to be safe, challenging existing security assumptions.