概要
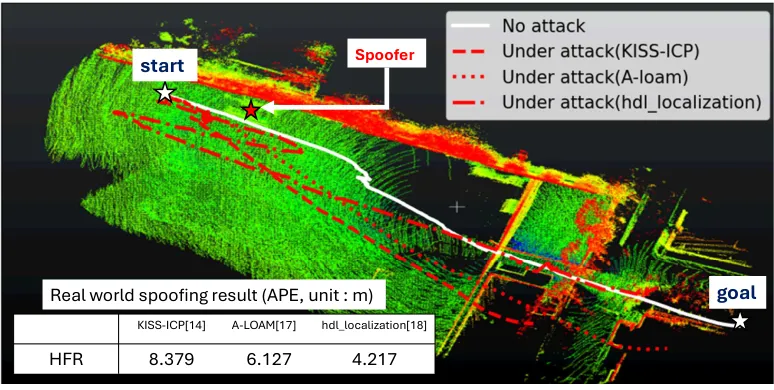
スキャンマッチングの脆弱性解析に基づく、SLAM型自己位置推定システムへの実践的LiDARスプーフィング攻撃を提案。慎重に設計した偽造点群の注入により、車両の自己位置認識を攻撃者の意図通りに操作できることを実証した。自動運転システムの安全設計に重要な知見を与える。
Practical LiDAR spoofing attacks targeting SLAM-based localization systems, guided by scan matching vulnerability analysis. Demonstrates that adversaries can manipulate vehicle localization by injecting carefully crafted ghost points into LiDAR scans.